3D Gaussian Splatting(Kerbl 等人,2023)
選讀・DLCV 11・三維重建:從多視角幾何到 NeRF 與 Gaussian Splatting 的論文導讀(第 2/3 篇)。引用編號對應本頁底部的參考文獻。
導覽:本頁與本系列: 導覽:本頁與本系列
挑戰
場景表示即使能產生漂亮新視角,也可能慢到不能互動。3D Gaussian Splatting [6] 將明確可最佳化的表示與 GPU 光柵器結合,目標是高品質即時渲染。表示與渲染工程是不同、但互相合作的貢獻。
方法
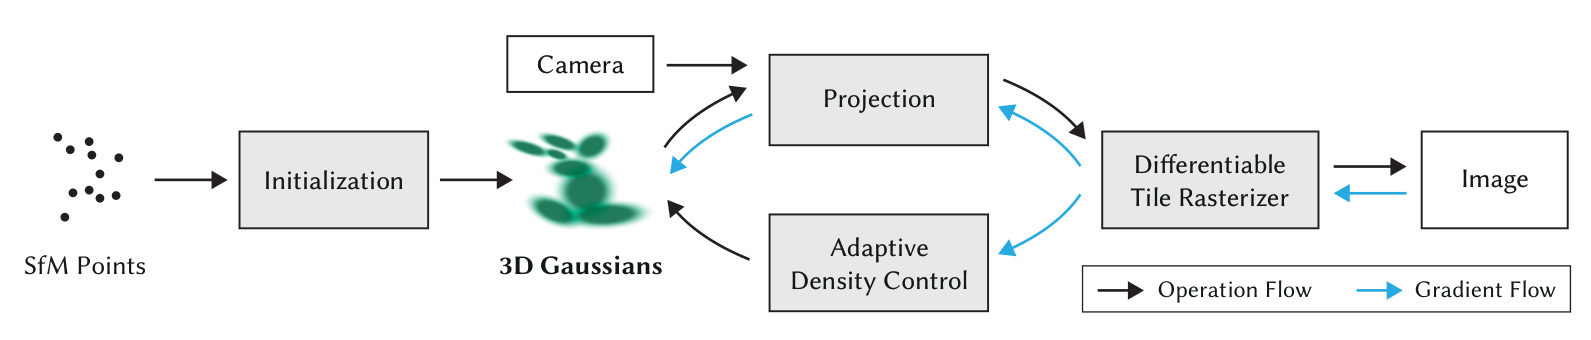
圖片來源: [6], arXiv:2308.04079v1, PDF 第 5 頁. 原始 PDF.
從校準觀測開始。 以運動恢復結構的點初始化高斯中心;每個基元具有三維位置、不透明度、非等向協方差與球諧色彩係數。旋轉與正尺度參數構成有效協方差,非等向性則容許基元沿表面伸展,而不只是一顆球。
投影、排序、混合。 渲染器把高斯投影成螢幕足跡,分派到區塊,再依可見性排序進行 alpha 混合。像素合成可寫成:
結合基元不透明度與投影高斯在該像素的作用, 是視角相關 RGB, 是前方排序基元之後的透射率。投影不透明度並不等同 NeRF 的取樣體積密度;區塊排序是有效率的近似,不是任意光線精確體積積分。
同時最佳化參數與基元數量。 重建損失結合像素與結構,梯度更新基元屬性;自適應密度控制則複製、分裂有用高斯,並移除無效基元。因此不只是最佳化一組固定點雲,表示本身也會改變。
快速可微分光柵器讓許多可見基元取得梯度;球諧函數表示方向外觀,無須每條光線都查詢大型神經網路。推論時對新相機投影、混合已最佳化的場景。
結果
Table 1 在真實場景資料集比較品質、訓練時間、渲染速度與儲存量,顯示達到互動渲染目標且品質有競爭力。表格區分引用基準與作者重跑結果,解讀速度/品質差異時應保留此區別。
標準真實場景流程每八個視角保留一個測試;觀測覆蓋與相機校準很重要。這是多張觀測重建,不是從單張照片還原任意未見場景。
消融實驗
Table 3 與第 7.3 節改變 SfM 初始化、自適應密度控制、非等向協方差、梯度參與及球諧外觀,將品質連接到表示與最佳化/渲染實作。
複製與分裂處理不同重建情況;限制貢獻或梯度可能刪掉有用背景證據,以單一尺度取代非等向形狀則減少表示彈性。這支持它們在測試設定中的角色,不代表每增加一個高斯或方向係數都一定改善所有場景。
結論
3DGS 用明確投影基元、排序與混合,取代重複神經光線行進,並在最佳化時調整基元族群。速度來自表示、最佳化器與光柵器的整體設計。
限制與問題
觀測不足的區域可能產生拉長或漂浮高斯,可見性改變也可能出現跳動。儲存/記憶體可能遠高於精簡神經場,相機誤差與靜態場景假設仍有限制。視覺可信的 splat 表示不自動等於乾淨網格,也不保證正確描述透明、反光表面的物理性質。
參考文獻
- R. Hartley and A. Zisserman, Multiple View Geometry in Computer Vision, 2nd ed., Cambridge University Press, 2004. doi
- J. L. Schönberger and J.-M. Frahm, “Structure-from-motion revisited,” in Proc. IEEE CVPR, 2016. CVF
- J. L. Schönberger, E. Zheng, J.-M. Frahm and M. Pollefeys, “Pixelwise view selection for unstructured multi-view stereo,” in Proc. ECCV, 2016. doi
- J. L. Schönberger et al., “COLMAP,” official documentation (general-purpose structure-from-motion and multi-view stereo pipeline). link
- B. Mildenhall, P. P. Srinivasan, M. Tancik, J. T. Barron, R. Ramamoorthi and R. Ng, “NeRF: Representing scenes as neural radiance fields for view synthesis,” in Proc. ECCV, 2020; also Communications of the ACM, vol. 65, no. 1, pp. 99–106, 2022. doi · CACM doi · arXiv
- B. Kerbl, G. Kopanas, T. Leimkühler and G. Drettakis, “3D Gaussian Splatting for real-time radiance field rendering,” ACM Transactions on Graphics, vol. 42, no. 4, 2023. doi · arXiv
- H. C. Longuet-Higgins, “A computer algorithm for reconstructing a scene from two projections,” Nature, vol. 293, pp. 133–135, 1981. doi
- R. I. Hartley, “In defense of the eight-point algorithm,” IEEE TPAMI, vol. 19, no. 6, pp. 580–593, 1997. doi
- D. Nistér, “An efficient solution to the five-point relative pose problem,” IEEE TPAMI, vol. 26, no. 6, pp. 756–770, 2004. doi
- M. A. Fischler and R. C. Bolles, “Random sample consensus: A paradigm for model fitting with applications to image analysis and automated cartography,” Communications of the ACM, vol. 24, no. 6, pp. 381–395, 1981. doi
- D. G. Lowe, “Distinctive image features from scale-invariant keypoints,” International Journal of Computer Vision, vol. 60, no. 2, pp. 91–110, 2004. doi
- N. Snavely, S. M. Seitz and R. Szeliski, “Photo tourism: Exploring photo collections in 3D,” ACM Transactions on Graphics, vol. 25, no. 3, pp. 835–846, 2006. doi
- B. Triggs, P. F. McLauchlan, R. I. Hartley and A. W. Fitzgibbon, “Bundle adjustment — A modern synthesis,” in Vision Algorithms: Theory and Practice, LNCS 1883, pp. 298–372, Springer, 2000. doi
- R. T. Collins, “A space-sweep approach to true multi-image matching,” in Proc. IEEE CVPR, pp. 358–363, 1996. doi
- B. Curless and M. Levoy, “A volumetric method for building complex models from range images,” in Proc. SIGGRAPH, pp. 303–312, 1996. doi
- Y. Yao, Z. Luo, S. Li, T. Fang and L. Quan, “MVSNet: Depth inference for unstructured multi-view stereo,” in Proc. ECCV, 2018. CVF · doi
- N. Max, “Optical models for direct volume rendering,” IEEE Transactions on Visualization and Computer Graphics, vol. 1, no. 2, pp. 99–108, 1995. doi
- M. Tancik, P. P. Srinivasan, B. Mildenhall, S. Fridovich-Keil, N. Raghavan, U. Singhal, R. Ramamoorthi, J. T. Barron and R. Ng, “Fourier features let networks learn high frequency functions in low dimensional domains,” in Proc. NeurIPS, 2020. proceedings
- T. Müller, A. Evans, C. Schied and A. Keller, “Instant neural graphics primitives with a multiresolution hash encoding,” ACM Transactions on Graphics, vol. 41, no. 4, 2022. doi · arXiv
- J. J. Park, P. Florence, J. Straub, R. Newcombe and S. Lovegrove, “DeepSDF: Learning continuous signed distance functions for shape representation,” in Proc. IEEE/CVF CVPR, 2019. CVF
- L. Mescheder, M. Oechsle, M. Niemeyer, S. Nowozin and A. Geiger, “Occupancy networks: Learning 3D reconstruction in function space,” in Proc. IEEE/CVF CVPR, 2019. CVF
- P. Wang, L. Liu, Y. Liu, C. Theobalt, T. Komura and W. Wang, “NeuS: Learning neural implicit surfaces by volume rendering for multi-view reconstruction,” in Proc. NeurIPS, 2021. proceedings · arXiv
- M. Zwicker, H. Pfister, J. van Baar and M. Gross, “EWA volume splatting,” in Proc. IEEE Visualization, 2001. doi
- W. E. Lorensen and H. E. Cline, “Marching cubes: A high resolution 3D surface construction algorithm,” in Proc. SIGGRAPH, pp. 163–169, 1987. doi
- M. Kazhdan, M. Bolitho and H. Hoppe, “Poisson surface reconstruction,” in Proc. Eurographics Symposium on Geometry Processing, 2006. doi
- M. Kazhdan and H. Hoppe, “Screened Poisson surface reconstruction,” ACM Transactions on Graphics, vol. 32, no. 3, 2013. doi
- A. Guédon and V. Lepetit, “SuGaR: Surface-aligned Gaussian splatting for efficient 3D mesh reconstruction and high-quality mesh rendering,” in Proc. IEEE/CVF CVPR, 2024. CVF · arXiv
- B. Huang, Z. Yu, A. Chen, A. Geiger and S. Gao, “2D Gaussian splatting for geometrically accurate radiance fields,” in Proc. SIGGRAPH (Conference Papers), 2024. doi · arXiv
- S. Wang, V. Leroy, Y. Cabon, B. Chidlovskii and J. Revaud, “DUSt3R: Geometric 3D vision made easy,” in Proc. IEEE/CVF CVPR, 2024. CVF · arXiv
- V. Leroy, Y. Cabon and J. Revaud, “Grounding image matching in 3D with MASt3R,” in Proc. ECCV, 2024. doi · arXiv
- J. Wang, M. Chen, N. Karaev, A. Vedaldi, C. Rupprecht and D. Novotny, “VGGT: Visual geometry grounded transformer,” in Proc. IEEE/CVF CVPR, 2025. CVF · arXiv
- A. Pumarola, E. Corona, G. Pons-Moll and F. Moreno-Noguer, “D-NeRF: Neural radiance fields for dynamic scenes,” in Proc. IEEE/CVF CVPR, 2021. CVF
- G. Wu, T. Yi, J. Fang, L. Xie, X. Zhang, W. Wei, W. Liu, Q. Tian and X. Wang, “4D Gaussian splatting for real-time dynamic scene rendering,” in Proc. IEEE/CVF CVPR, 2024. CVF · arXiv
- Z. Wang, A. C. Bovik, H. R. Sheikh and E. P. Simoncelli, “Image quality assessment: From error visibility to structural similarity,” IEEE Transactions on Image Processing, vol. 13, no. 4, pp. 600–612, 2004. doi
- R. Zhang, P. Isola, A. A. Efros, E. Shechtman and O. Wang, “The unreasonable effectiveness of deep features as a perceptual metric,” in Proc. IEEE/CVF CVPR, 2018. CVF
- H. Fan, H. Su and L. J. Guibas, “A point set generation network for 3D object reconstruction from a single image,” in Proc. IEEE CVPR, 2017. CVF
- R. Jensen, A. Dahl, G. Vogiatzis, E. Tola and H. Aanæs, “Large scale multi-view stereopsis evaluation,” in Proc. IEEE CVPR, pp. 406–413, 2014. doi
- A. Knapitsch, J. Park, Q.-Y. Zhou and V. Koltun, “Tanks and Temples: Benchmarking large-scale scene reconstruction,” ACM Transactions on Graphics, vol. 36, no. 4, 2017. doi · benchmark
- J. T. Barron, B. Mildenhall, D. Verbin, P. P. Srinivasan and P. Hedman, “Mip-NeRF 360: Unbounded anti-aliased neural radiance fields,” in Proc. IEEE/CVF CVPR, 2022. CVF · arXiv
- D. Verbin, P. Hedman, B. Mildenhall, T. Zickler, J. T. Barron and P. P. Srinivasan, “Ref-NeRF: Structured view-dependent appearance for neural radiance fields,” in Proc. IEEE/CVF CVPR, 2022. CVF
- C.-H. Lin, W.-C. Ma, A. Torralba and S. Lucey, “BARF: Bundle-adjusting neural radiance fields,” in Proc. IEEE/CVF ICCV, 2021. CVF
- S. M. Seitz, B. Curless, J. Diebel, D. Scharstein and R. Szeliski, “A comparison and evaluation of multi-view stereo reconstruction algorithms,” in Proc. IEEE CVPR, vol. 1, pp. 519–528, 2006. doi
- Y. Furukawa and C. Hernández, “Multi-view stereo: A tutorial,” Foundations and Trends in Computer Graphics and Vision, vol. 9, no. 1–2, pp. 1–148, 2015. doi
- A. Tewari, J. Thies, B. Mildenhall, P. Srinivasan, E. Tretschk, W. Yifan, C. Lassner, V. Sitzmann et al., “Advances in neural rendering,” Computer Graphics Forum, vol. 41, no. 2, pp. 703–735, 2022. doi · arXiv
- G. Chen and W. Wang, “A survey on 3D Gaussian splatting,” ACM Computing Surveys, vol. 58, no. 12, 2026. doi · arXiv
- scikit-image contributors, “skimage.measure.marching_cubes,” scikit-image documentation (API reference). docs
- A. Dosovitskiy, L. Beyer, A. Kolesnikov, D. Weissenborn, X. Zhai et al., “An image is worth 16x16 words: Transformers for image recognition at scale,” in Proc. ICLR, 2021. arXiv
- A. Vaswani, N. Shazeer, N. Parmar, J. Uszkoreit, L. Jones, A. N. Gomez, Ł. Kaiser and I. Polosukhin, “Attention is all you need,” in Proc. NeurIPS, 2017. proceedings
- D. P. Kingma and J. Ba, “Adam: A method for stochastic optimization,” in Proc. ICLR, 2015. arXiv