IP 11 · Image Segmentation II: Active Contours — Snakes and Level Sets
Needs: IP 10 · Image Segmentation I: Edge Detection, Thresholding, and Region Detection
Navigate: this page and this track: Navigate: this page and this track
Explore this chapter 1 interactive experiment
Run a real snake, the Kass–Witkin–Terzopoulos contour of IP 11, on a photograph of coins: start a circle around one coin and see how far from its rim the circle may begin before the snake settles in the wrong place.
What you’ll learn
- Why segmentation can be posed as moving a curve until an energy stops decreasing, and what that buys over thresholding and edge linking.
- How a snake (an explicit, parametric active contour) is defined by internal and external energies, and how the Euler–Lagrange equation turns that energy into an iterative algorithm.
- How to pick the external force: image gradients, edge maps, gradient vector flow (GVF) and the balloon force, and why each one exists.
- How the level-set method represents a curve implicitly as the zero crossing of a function , and how to evolve it with using upwind finite differences under a CFL limit.
- How the speed function encodes edge-based (geodesic active contours) and region-based (Chan–Vese, from Mumford–Shah) models, plus signed-distance reinitialization, narrow bands and morphological approximations.
- Where active contours live today: inside deep networks as contour-refinement heads and as loss functions.
The big picture
IP 10 segmented images with local rules: threshold this pixel, link that edge, grow this region. Those rules know nothing about the shape of what they produce. The result can be a boundary with gaps, a region that leaks through a weak edge, or a speckle of isolated pixels.
Active contours take a different view. We start with a closed curve somewhere near the object and let it move. The curve is pushed by the image (toward edges, or toward a good split into “inside” and “outside”) and held together by its own stiffness (it resists stretching and bending). When the pushes and the stiffness balance, the curve stops, and its final position is the segmentation. The output is always a closed, smooth boundary, never a heap of edge fragments.
Following the textbook [1], this chapter covers the two families in that order. Snakes (Kass, Witkin and Terzopoulos [2]) store the curve as a list of points and move the points directly. Level sets (Osher and Sethian [5]) store the curve implicitly as the zero contour of a surface and move the surface instead, which makes splitting and merging automatic. Both are variational: we write down an energy, then do gradient descent on it. That idea, more than any particular formula, is what survived into deep learning.
Background: why curves that move
In plain words: instead of deciding pixel by pixel, we describe the whole boundary at once and ask, “how good is this boundary?” Then we improve it a little at a time.
More precisely, an active contour method has three ingredients:
- A representation of a closed curve in the image domain : either explicit (a parametrized curve ) or implicit (the zero level set of a function ).
- An energy that is low when is a good boundary. It always mixes a regularity term (short, smooth curves are preferred) with a data term (edges are strong along the curve, or the regions inside and outside are each homogeneous).
- An evolution rule that changes to decrease , usually gradient descent written as a partial differential equation (PDE) in an artificial time .
Compared with IP 10, the regularity term bridges gaps in edges, the output is always a closed curve ready for the shape descriptors of IP 12, and prior knowledge (a user’s click, a smoothness preference, an intensity model) enters naturally.
The price is that the energy is non-convex: gradient descent finds a local minimum, so the answer depends on where you start.
Image segmentation using snakes
A snake is a closed chain of points that slides over the image. Each point feels two kinds of pull: its neighbours keep the chain short and smooth, and the image drags it toward edges.
The snake as a parametric curve
We write the contour as
where is a parameter that runs once around the curve and , are image coordinates. Derivatives with respect to are written and . In a computer the curve is sampled at points , , with indices taken modulo for a closed snake.
The energy functional
In plain words: the energy gives every curve a score. It adds up how stretched and how bent the curve is, plus an image term that is low where we want the curve to settle; the snake looks for the curve with the lowest score.
The snake energy of [2] is
- is the elasticity (tension) weight. The term is large when the curve is stretched, so makes the snake behave like an elastic string that wants to shrink.
- is the rigidity (bending) weight. The term measures how sharply the curve turns, so makes the snake behave like a thin metal rod that resists kinks.
- is the external (image) energy, a scalar field over the image that is low where we want the snake to settle.
A common choice of external energy for a gray-level image is
where is a Gaussian of standard deviation , is convolution, is the gradient, and , are weights. With the snake is attracted to strong edges. With it is attracted to dark lines, and with to bright lines. The Gaussian blur widens the valleys of so that the snake can feel an edge from a few pixels away; [2] calls this scale-space continuation.
From energy to motion: the Euler–Lagrange equation
To minimize this energy we use the calculus of variations: a minimizing curve must satisfy the Euler–Lagrange equation of the integrand. For constant and it reads
Read it as a force balance. is the tension force (it points toward the local centre of curvature and shortens the curve), is the bending force (it straightens kinks), and is the image force. At equilibrium they cancel.
We rarely can solve this equation directly, so we make depend on an artificial time and let it slide downhill:
where is a viscosity (damping) constant. When we are back at the Euler–Lagrange equation.
Optional: Deriving the snake equation (in the Supplementary notes). How the general Euler–Lagrange equation gives the snake’s force balance.
Discretization and the iterative solution
In plain words: once the curve is sampled at points, the smoothness forces become one fixed matrix, so each step of the snake costs a single matrix–vector product per coordinate.
Sample the curve at points with unit spacing. Central differences give
Stack the coordinates into a vector (and likewise ). Then , where is a symmetric, circulant, pentadiagonal matrix whose rows contain
centred on the diagonal (wrapping around at the ends). The internal forces are linear in the point positions; the external force is not. The classic trick of [2] is a semi-implicit step: treat the internal part implicitly (at the new time ) and the external part explicitly (at the old time ):
and the same for with . Here , are the components of sampled (by interpolation) at the current points, and is the identity. The matrix is fixed, so it is inverted or factorized once; each iteration is then a cheap matrix–vector product. The implicit treatment of the stiff fourth-order term is what lets the snake take reasonable steps without blowing up. The step size is : a larger means smaller, safer steps.
Code · Python · 13 lines
import numpy as np

def snake_step_matrix(n, alpha, beta, gamma):
    """(A + gamma*I)^-1 for a closed snake with n points (h = 1)."""
    row = np.zeros(n)
    row[[0, 1, 2, -2, -1]] = [2*alpha + 6*beta, -alpha - 4*beta, beta,
                              beta, -alpha - 4*beta]
    A = np.stack([np.roll(row, i) for i in range(n)])
    return np.linalg.inv(A + gamma * np.eye(n))

M = snake_step_matrix(100, alpha=0.05, beta=0.05, gamma=1.0)
# one iteration, given external forces fx, fy sampled at the points:
# x = M @ (gamma * x + fx);  y = M @ (gamma * y + fy)
scikit-image’s active_contour builds the same internal-energy matrix and offers the edge and line energies above, but it is not an exact copy of the update above: it computes the image gradient itself and caps how far a point may move per iteration [12]:
Code · Python · 13 lines
import numpy as np
from skimage import data
from skimage.color import rgb2gray
from skimage.filters import gaussian
from skimage.segmentation import active_contour

img = rgb2gray(data.astronaut())
s = np.linspace(0, 2 * np.pi, 400)
init = np.column_stack([100 + 100 * np.sin(s),   # rows
                        220 + 100 * np.cos(s)])  # columns
snake = active_contour(gaussian(img, sigma=3), init,
                       alpha=0.015, beta=10, gamma=0.001)
print(snake.shape)  # (400, 2): the final (row, col) points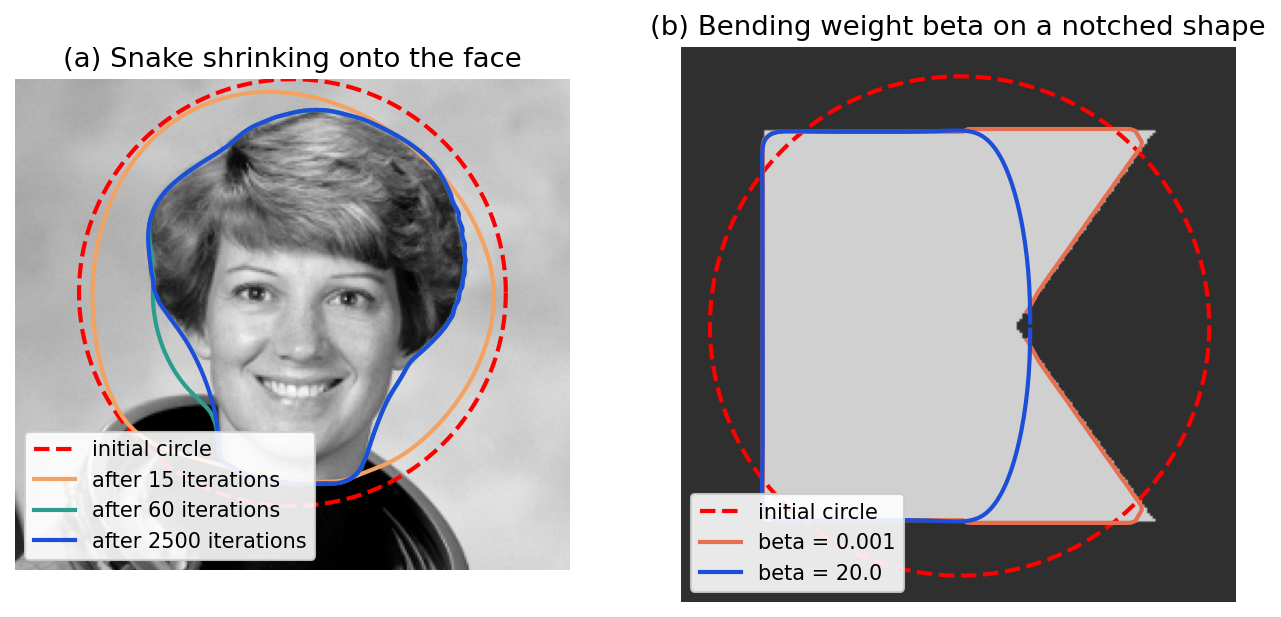
Figure 11.1(a) shows the typical life of a snake: it shrinks quickly through the flat background (tension alone), then slows as it enters the zone where the blurred edge map has a slope, and finally locks onto the strongest nearby edges. Panel (b) shows the trade-off that controls. A stiff snake is robust to noise and small gaps, but it cannot follow corners or concavities.
Choosing the external force
The external force decides what the snake looks for. Common choices:
- Gradient of an edge map. Compute an edge map that is large on edges, for example (or its square), and use with a weight . The force points uphill on , toward the ridge of the edge.
- Line attraction. Use to follow dark or bright curvilinear structures (roads, vessels, text strokes).
All of them share the same weakness. The gradient of an edge map is essentially zero away from edges (Figure 11.2a). A snake that starts far from the boundary feels nothing but its own tension. And inside a narrow concavity the forces from the two walls point sideways and cancel, so nothing pulls the snake down into it. These two problems, limited capture range and poor convergence into concavities, motivated GVF.
Gradient vector flow (GVF)
GVF keeps the good part of (accurate, pointing at edges where edges exist) and fills in the rest of the image by smooth diffusion. Xu and Prince [3] define the GVF field as the smoothest vector field that stays close to wherever is large; a weight balances the two and should grow with the noise level. The field is computed by iterating a diffusion equation: far from edges it simply diffuses outward from the edges, carrying their direction with it. The explicit update contains both diffusion and a reaction term pulling the field toward the edge gradient. Its time step must account for both: on a unit-spaced grid, the code uses . The factor is a conservative safety margin, not a parameter of the GVF energy.
Optional: The GVF energy and its diffusion equations (in the Supplementary notes). The functional of [3], what each term asks for, and the update equations the code iterates.
Code · Python · 23 lines
import numpy as np
from scipy import ndimage as ndi

def gvf(f, mu=0.2, iters=500):
    """GVF on a unit-spaced grid, with a conservative explicit time step."""
    f = np.asarray(f, dtype=float)
    if f.ndim != 2 or min(f.shape) < 2 or not np.isfinite(f).all():
        raise ValueError("f must be a finite 2-D array with both dimensions >= 2")
    if not np.isfinite(mu) or mu <= 0:
        raise ValueError("mu must be finite and positive")
    fy, fx = np.gradient(f)
    mag2 = fx**2 + fy**2
    dt = 0.9 / (4 * mu + mag2.max())  # diffusion AND reaction enter the bound
    u, v = fx.copy(), fy.copy()
    for _ in range(iters):
        u += dt * (mu * ndi.laplace(u, mode="nearest") - (u - fx) * mag2)
        v += dt * (mu * ndi.laplace(v, mode="nearest") - (v - fy) * mag2)
    return u, v

edge_map = np.array([[0., 1.], [1., 0.]])
u, v = gvf(edge_map, mu=0.25, iters=100)
print(np.isfinite(u).all() and np.isfinite(v).all())  # True
print(np.round(u, 3))  # [[ 0.8  0.8], [-0.8 -0.8]]
The snake then uses in place of , with no other change to the algorithm.
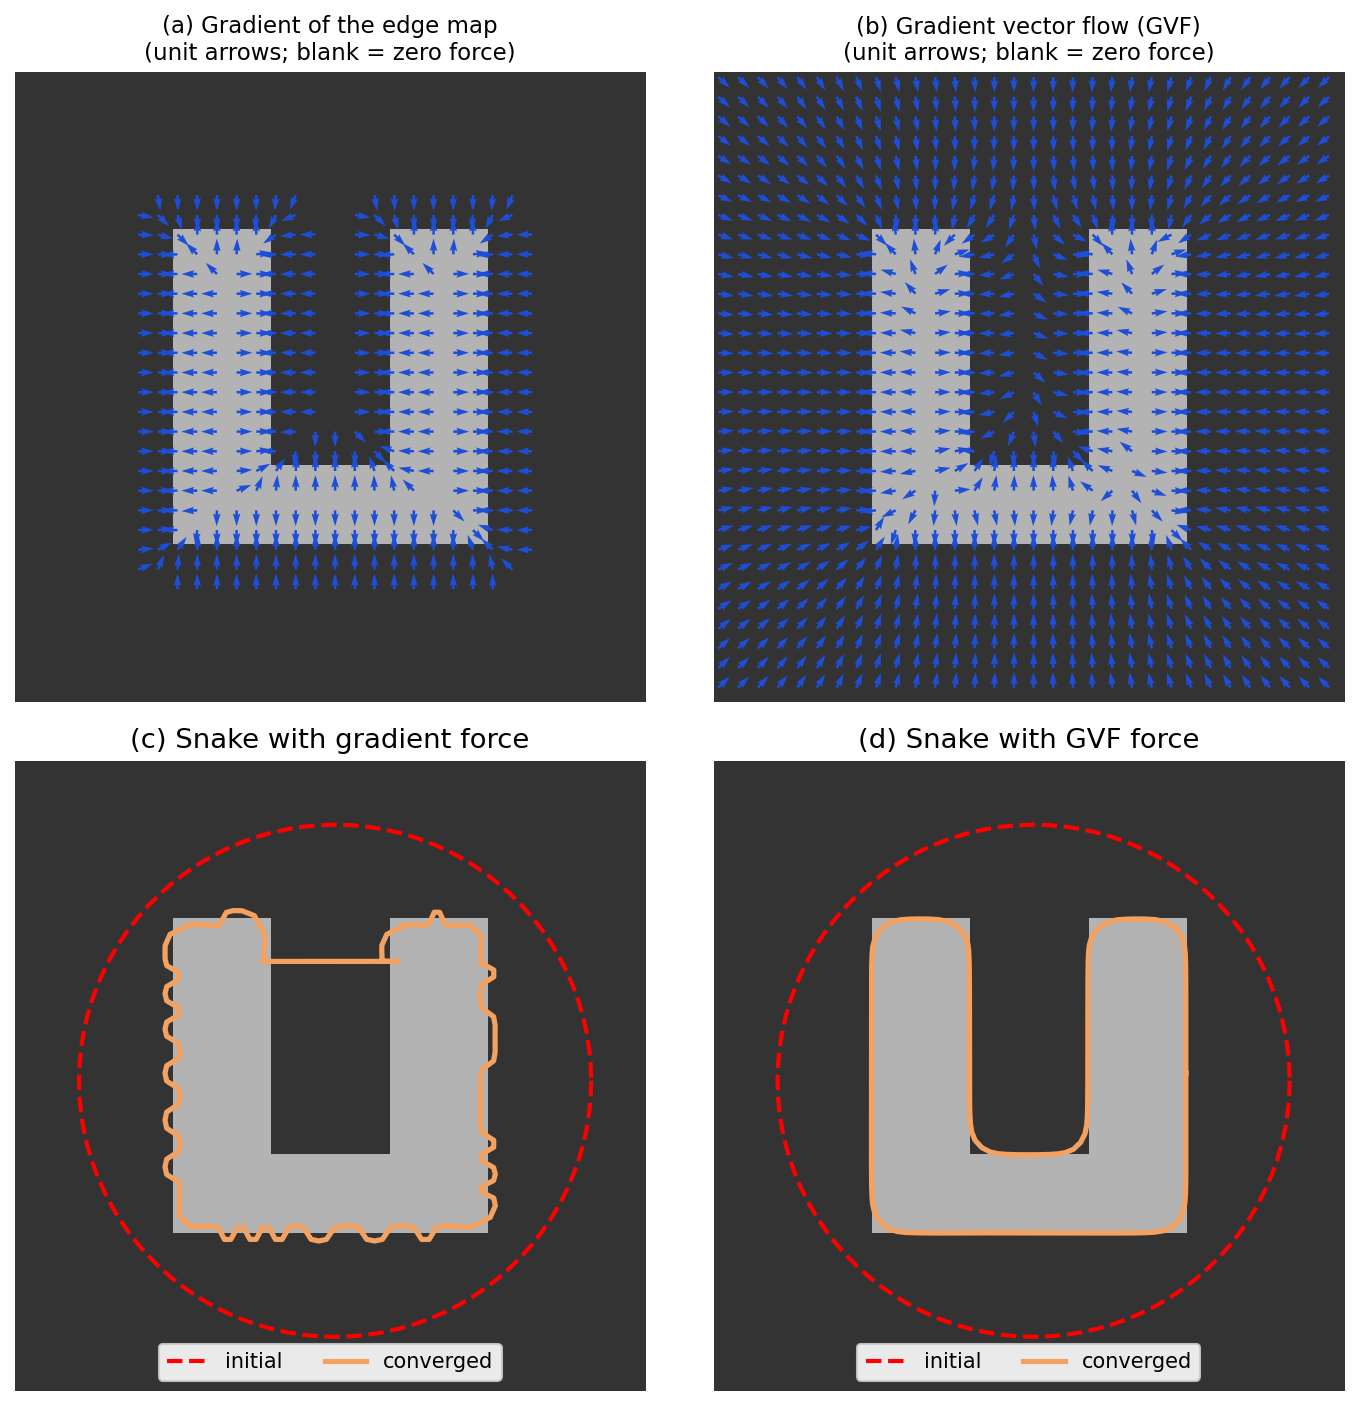
Figure 11.2 reproduces the classic test of [3] on a synthetic U shape. Two things changed: the snake now feels the object from anywhere in the image (large capture range), and inside the notch the diffused vectors point down rather than sideways, so the snake is pulled into the concavity. One implementation detail matters: as the snake enters the notch its length grows, so the points must be resampled to a roughly constant spacing every few dozen iterations, or the chain becomes too sparse to follow the walls.
The balloon force
Cohen [4] attacked the capture-range problem from another angle. If you initialize a small snake inside the object, tension makes it shrink to a point before any edge force can reach it. So add a pressure:
where is the unit outward normal of the curve at and is the pressure. With the snake inflates like a balloon; with it deflates. The edge force must be able to beat the pressure at a real boundary ( there), but not at the weak, noisy gradients inside the object. Cohen also suggests normalizing the edge force, , so that one constant controls its strength everywhere.
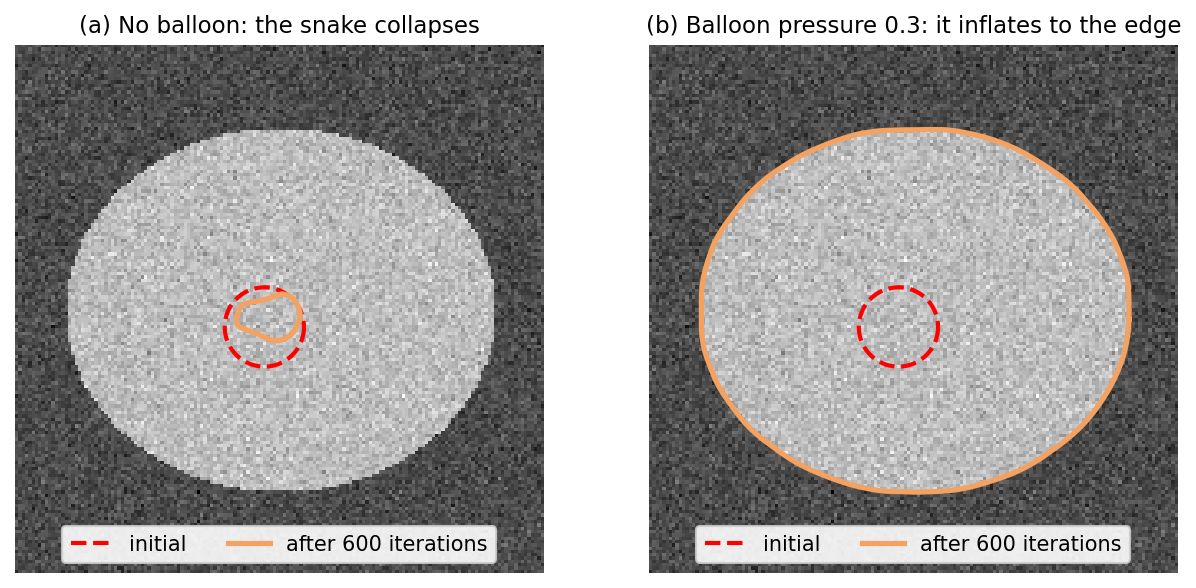
The balloon force has a cost: you must know in advance whether to inflate or deflate, and too much pressure carries the snake straight through weak edges. GVF and balloon forces are complementary and are often combined.
Limitations of snakes
- Initialization. The energy has many local minima. Even with GVF, a snake started across two objects or on the wrong side of a strong clutter edge will converge to the wrong answer.
- Parameter tuning. , , , , the blur , the pressure and the GVF interact. Values that work on one image often fail on the next.
- Point management. The points drift along the curve, bunch up in some places and spread out in others. Practical snakes resample the curve and must detect when it crosses itself.
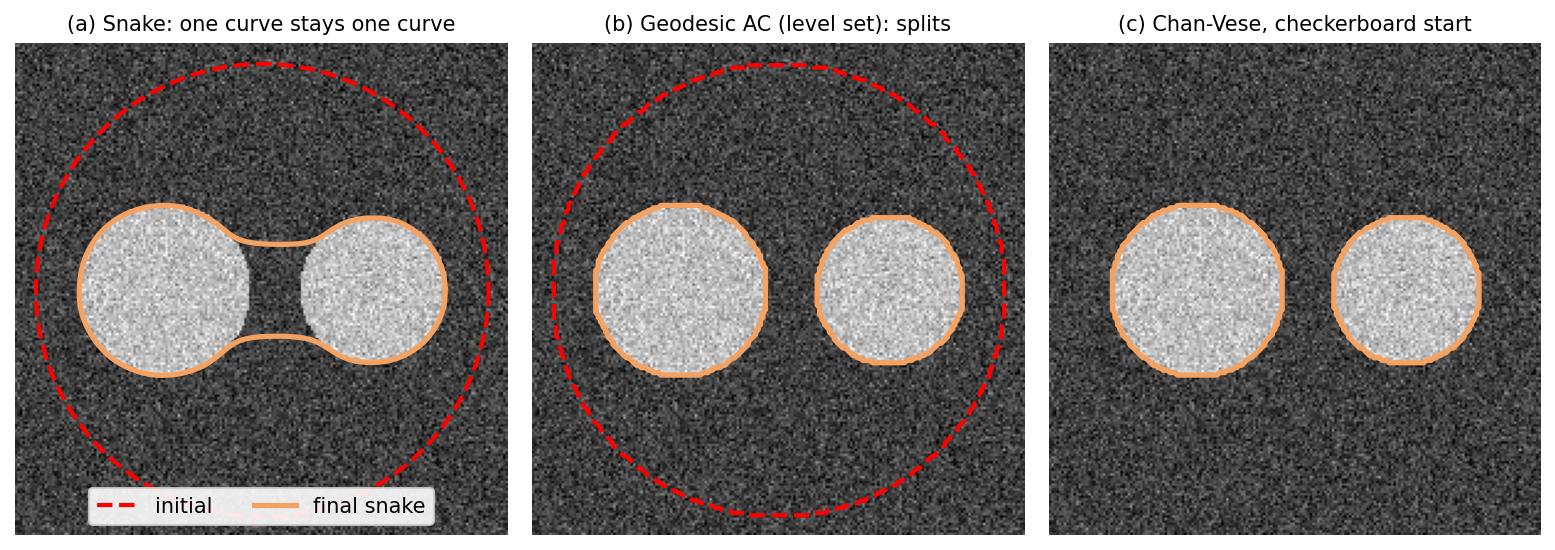
- Topology is fixed. A snake is one closed chain. It cannot split into two when it encloses two objects (Figure 11.6a), and it cannot merge with another snake, without extra, error-prone bookkeeping.
The last limitation is the one level sets remove.
Segmentation using level sets
Instead of tracking the boundary itself, track a landscape whose shoreline is the boundary. Move the landscape up or down, and the shoreline moves with it. If the water rises enough to separate two hills, the one shoreline becomes two, with no special code.
The implicit representation
In plain words: store a height at every pixel; the curve is the shoreline where the height is zero.
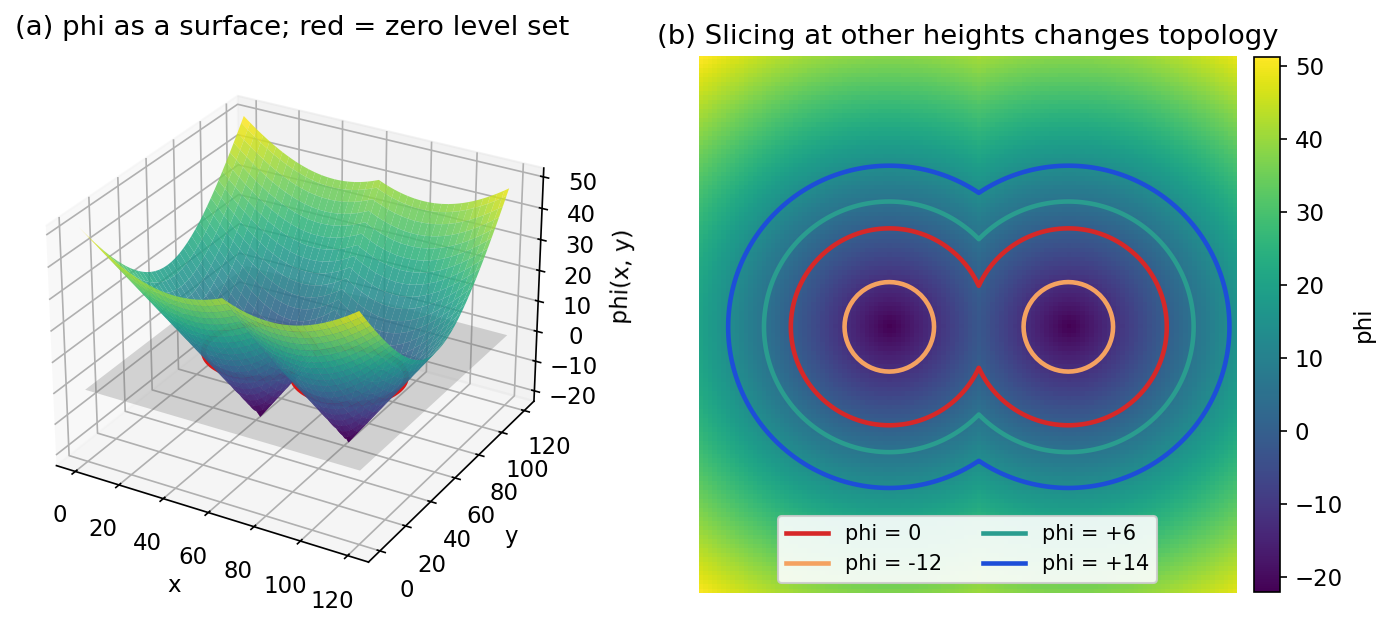
A level-set function is a scalar function such that the curve at time is its zero level set:
We use the convention inside the curve and outside. (Some papers, including [8], use the opposite sign; the equations change sign accordingly.) Two geometric quantities come for free from :
where is the unit outward normal and is the curvature of the level curve through each point (positive on convex parts; for a circle of radius , ).
The most convenient is the signed distance function: is the Euclidean distance from to , with the sign telling inside from outside. It satisfies almost everywhere, which keeps the numerics well behaved.
The level-set equation
Suppose each point of the curve moves along its outward normal with speed (positive means outward):
Points on the curve keep the value zero, so for all . Differentiate with the chain rule:
This is the level-set equation of Osher and Sethian [5]. is the time derivative of and is the speed function, which may depend on position (image data), on the geometry of the curve (curvature ), or on global statistics. The equation is solved on the fixed pixel grid for all , not only on the curve; the curve is read off at any time by extracting the zero contour. Nothing in the equation cares how many pieces the zero set has, which is why splitting and merging happen naturally.
Discrete computation: upwind differences and the CFL condition
In plain words: on a grid, the front must be updated with differences taken from the side it is coming from, the upwind side, as in the scheme of [5]. With the value at pixel after steps of size (grid spacing ), each step subtracts times an upwind estimate of built from one-sided differences; the evolve function below implements it. Using a plain central difference instead produces oscillations and corners that smear or explode; upwinding is what keeps the front sharp and stable.
Optional: The upwind scheme in formulas (in the Supplementary notes). The one-sided differences and the two upwind gradient estimates, written out.
The explicit scheme is stable only if the front moves less than one cell per step. This is the Courant–Friedrichs–Lewy (CFL) condition:
In practice you compute from the current maximum speed at each step, as the code below does.
Code · Python · 26 lines
import numpy as np
from scipy import ndimage as ndi

def signed_distance(mask):
    """Negative inside, positive outside, ~0 on the boundary."""
    return ndi.distance_transform_edt(~mask) - ndi.distance_transform_edt(mask)

def evolve(phi, F, steps=100, cfl=0.5):
    """Upwind scheme for phi_t + F |grad phi| = 0 (F is an array or scalar)."""
    for _ in range(steps):
        p = np.pad(phi, 1, mode="edge")
        dxm = phi - p[1:-1, :-2]; dxp = p[1:-1, 2:] - phi   # backward / forward
        dym = phi - p[:-2, 1:-1]; dyp = p[2:, 1:-1] - phi
        grad_plus = np.sqrt(np.maximum(dxm, 0)**2 + np.minimum(dxp, 0)**2 +
                            np.maximum(dym, 0)**2 + np.minimum(dyp, 0)**2)
        grad_minus = np.sqrt(np.minimum(dxm, 0)**2 + np.maximum(dxp, 0)**2 +
                             np.minimum(dym, 0)**2 + np.maximum(dyp, 0)**2)
        dt = cfl / (np.abs(F).max() + 1e-12)             # CFL: |F| dt <= dx
        phi = phi - dt * (np.maximum(F, 0) * grad_plus + np.minimum(F, 0) * grad_minus)
    return phi

yy, xx = np.mgrid[:128, :128]
phi = signed_distance((xx - 64)**2 + (yy - 64)**2 < 20**2)
phi = evolve(phi, F=1.0, steps=20)                # grow outward by 20 * 0.5 = 10 px
phi = signed_distance(phi < 0)                     # re-initialize
print(np.sqrt((phi < 0).sum() / np.pi))            # radius, about 30
Specifying the speed function
All the image analysis lives in . Two families dominate.
Edge-based speed: geodesic active contours
In plain words: make the front fast in flat regions and slow on edges, so that it stops where the edges are.
Define an edge-stopping function that is close to in flat regions and close to on edges, for example
Caselles, Kimmel and Sapiro [6] showed that a snake with is closely related to finding a curve of minimal weighted length
where is arc length. In the metric defined by , edges are “cheap” places to be, so a minimizer is a geodesic (shortest path) that hugs edges. This is the geodesic active contour (GAC). Gradient descent on , plus an optional constant pressure like Cohen’s balloon, gives in our sign convention
Each term has a job. is curvature flow (shortening and smoothing) that slows to a stop near edges. is the pressure: inflates, deflates, again switched off on edges. is an advection term that pulls the curve into the bottom of the edge valley, where is minimal, and stops it from overshooting. Unlike a snake, the GAC is intrinsic: it does not depend on how the curve is parametrized, and in level-set form it splits and merges freely.
Because never reaches exactly zero, a strong pressure still leaks through weak or blurred edges. That is the motivation for region-based speeds.
Region-based speed: Mumford–Shah and Chan–Vese
In plain words: instead of looking for edges, choose the curve that splits the image into an inside and an outside that are each as uniform as possible.
Mumford and Shah [7] posed segmentation as finding a piecewise-smooth approximation of the image together with a set of boundaries. Their energy balances three wishes: stay close to the image, be smooth everywhere except across the boundaries, and keep the boundaries short. This energy is hard to minimize in general.
Optional: The Mumford–Shah energy (in the Supplementary notes). The full functional and what each of its three terms asks for.
Chan and Vese [8] restricted to be piecewise constant with two values: inside and outside. The energy becomes
(the original also has an optional area term , usually set to zero). weights smoothness and weight how well each region is fitted by its constant. Note what is missing: there is no gradient. The model can segment objects whose boundaries are blurred or defined only by a change of average intensity, which is why [8] called it “active contours without edges”.
To write this in level-set form, use the Heaviside function ( for , otherwise) and its derivative, the Dirac delta . With inside, the inside indicator is and the length is . For fixed , the optimal constants are the region means
For fixed , gradient descent in gives
where is a smoothed delta of width . Read it pixel by pixel: if a pixel’s intensity is far from but close to , the bracket is positive, rises, and the pixel moves outside. The curvature term keeps the boundary short. The algorithm alternates between updating the means and updating . Because is non-zero away from the zero level set, the model can also create new contours far from the initial one, which helps detect interior holes and disconnected objects in the examples of [8]. This behavior depends on the chosen regularization; the nonconvex energy can still converge to different local minima from different initial curves.
Optional: Chan–Vese (in the Paper guides). Read the original region-fitting diagram, the initialization caveat and the difference between fitting energy and the complete objective.
Chan–Vese is one member of a larger family of region-based models: any probability model of the regions can take the place of the two constants [14].
Optional: Other region models (in the Supplementary notes). How the same structure works with Gaussian, color, texture or motion models.
Code · Python · 8 lines
from skimage import data, img_as_float
from skimage.segmentation import chan_vese, morphological_chan_vese

cam = img_as_float(data.camera())
seg, phi, energies = chan_vese(cam, mu=0.25, lambda1=1, lambda2=1,
                               dt=0.5, max_num_iter=200, extended_output=True)
fast = morphological_chan_vese(cam, num_iter=100, init_level_set="checkerboard",
                               smoothing=3)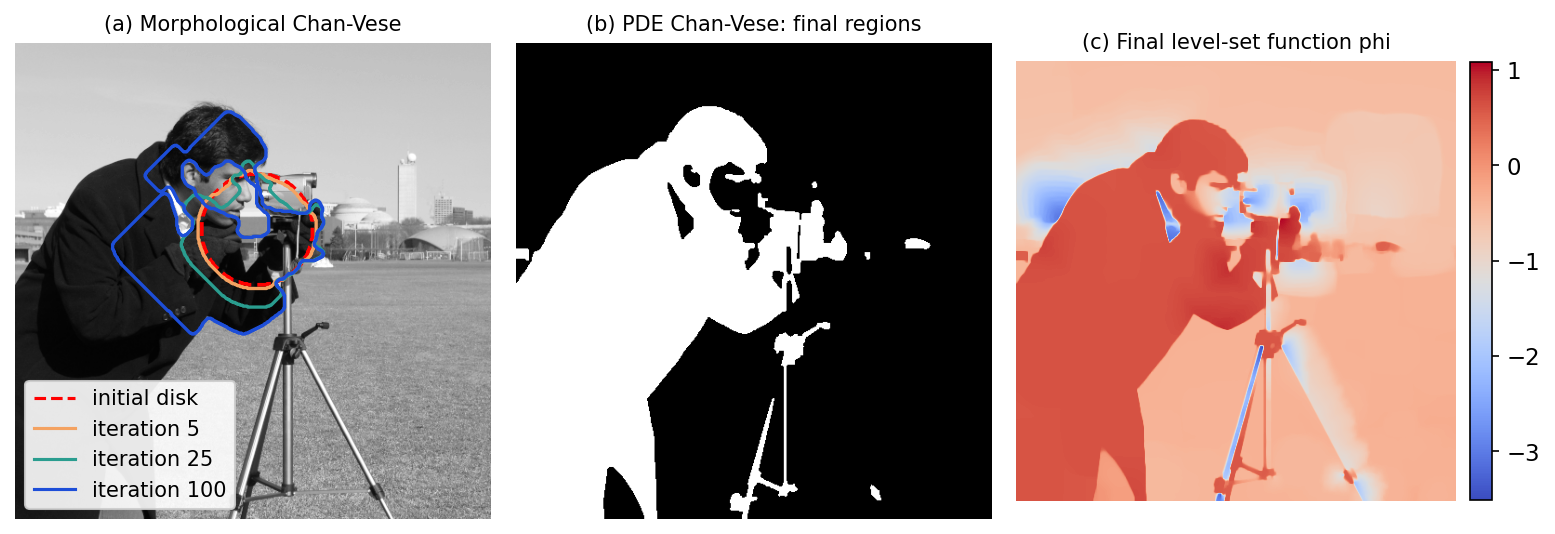
Initializing and reinitializing as a signed distance function
The initial is usually the signed distance to a user-drawn curve, a box, a disk, or many small circles (a “checkerboard”) so that the evolution starts near every possible object. As the PDE runs, drifts away from a distance function: it becomes very steep in some places and very flat in others. Steep regions force tiny time steps; flat regions make the zero crossing poorly located and sensitive to noise.
The classical remedy is reinitialization: every few iterations, replace by the signed distance to its current zero level set without moving that zero set, for example with a fast Euclidean distance transform as in the code above. Li, Xu, Gui and Fox [10] proposed distance-regularized level-set evolution (DRLSE), which adds an energy penalty that keeps close to and so removes the need for reinitialization.
Optional: Reinitialization and DRLSE in detail (in the Supplementary notes). The PDE alternative to the distance transform, its drawbacks, and the DRLSE penalty.
Improving efficiency
A full-grid level-set solver updates every pixel at every step, although only the zero crossing matters. Three standard speed-ups:
- Narrow band. Adalsteinsson and Sethian [9] update only within a band of half-width (a few pixels) around the zero level set. When the front approaches the edge of the band, the band is rebuilt around the new front (with a reinitialization). The work per step drops from the image area to roughly the curve length times .
- Larger stable steps. Semi-implicit or operator-splitting schemes allow larger for the stiff curvature term, at the cost of solving a linear system per step.
- Morphological approximations. Márquez-Neila, Baumela and Álvarez [11] replace the PDE by a sequence of binary morphological operators (dilations, erosions and smoothing operators) acting on a binary level set. The result is fast, has no time step, needs no reinitialization and never becomes unstable.
scikit-image provides morphological_geodesic_active_contour and morphological_chan_vese based on [11], alongside the PDE-based chan_vese [12]. Keep in mind that the morphological variants approximate the PDEs. They move on the pixel grid, their “smoothing” parameter is a number of operator applications rather than the weight , and their results are close to, not identical with, the continuous models.
Optional: How the morphological approximation works (in the Supplementary notes). Which operator replaces which PDE term, and what was proved about them.
Code · Python · 9 lines
from skimage import data, img_as_float
from skimage.segmentation import (inverse_gaussian_gradient, disk_level_set,
                                  morphological_geodesic_active_contour)

coins = img_as_float(data.coins())
g = inverse_gaussian_gradient(coins, alpha=100, sigma=2)   # ~0 on edges, ~1 elsewhere
init = disk_level_set(coins.shape, radius=150)
mask = morphological_geodesic_active_contour(g, num_iter=250, init_level_set=init,
                                             smoothing=1, balloon=-1, threshold=0.69)
Here inverse_gaussian_gradient builds the edge-stopping function , balloon=-1 shrinks the initial disk (the role of ), and threshold decides which values of count as edges that stop the balloon.
Snakes vs level sets in practice
Both families minimize similar energies. The difference is mostly in representation, and the representation decides what is easy.
In short: a snake has few unknowns (its points), is cheap per iteration, is easy to edit interactively and can carry point labels, but its topology is fixed and its points drift and can cross. A level set has one unknown per pixel (or per band pixel), but it splits and merges automatically, cannot self-intersect and extends directly to 3D. Their typical failures differ too: snakes stall on clutter or in concavities, edge-based level sets leak through weak edges, and region-based ones merge similar-looking regions.
Optional: Snakes vs level sets, point by point (in the Supplementary notes). A ten-row comparison table of the two representations.
Xu, Yezzi and Prince studied the relationship between the two formulations [3]; for many energies the choice is about implementation, not about what can be modeled in principle. A rule of thumb:
- Use a snake when you need one boundary of known topology, interactively, fast, or with point correspondences (tracking a contour across video frames, fitting a lip outline, delineating a building footprint).
- Use a level set when the number of objects is unknown, objects may touch or split, the boundary is ill-defined by gradients (region-based models), or you work in 3D.
Modern view
Active contours are no longer the default way to segment an image; deep networks are. But the ideas of this chapter, energies that combine boundary length with region fit, explicit contours deformed iteratively, and level sets as a shape representation, are still active ingredients in deep segmentation. Six papers give a good map.
Deformable models in medical imaging. McInerney and Terzopoulos [13] wrote the standard early survey. Its main takeaway still holds: deformable models are most useful when the image alone is ambiguous and the model must contribute smoothness and prior knowledge.
Statistical region-based level sets. Cremers, Rousson and Deriche [14] derive region-based level-set methods from one Bayesian framework in which each region gets a probability model (intensity, color, texture or motion). They argue that region-based energies are less sensitive to noise and have fewer local minima than edge-based snakes.
A recent taxonomy. Chen, Ge, Wang and Chen [15] sort active contour models into edge-based, region-based and hybrid families and compare them with deep segmentation. Classical models need no training data and give smooth closed boundaries but are sensitive to initialization and parameters; deep models are more accurate where labelled data exist; the two are complementary.
Shape constraints in deep segmentation. Bohlender, Oksuz and Mukhopadhyay [16] survey how shape knowledge, including active contours and signed distance maps, is injected into deep medical image segmentation to fix the fragmented regions and topological errors of pixel-wise classifiers.
Optional: The four surveys in more detail (in the Paper guides). What each survey covers and how it organizes the field.
Explicit contours learned end to end. Deep Snake by Peng et al. [17] keeps the snake’s representation, a closed polygon deformed iteratively, but learns the update: a circular convolution over CNN features sampled at the vertices predicts per-vertex offsets toward the boundary, and the authors report real-time speed for instance segmentation. The circular convolution plays the role of the classical snake’s pentadiagonal matrix : it couples each vertex to its neighbours along the closed curve.
Active-contour energies as loss functions. Instead of running a contour at test time, several methods put the energy into the training loss: a supervised Chan–Vese-like loss with length and region terms [18], a label-free Mumford–Shah-style loss on a network’s softmax outputs that also supports unsupervised and semi-supervised training [19], and the boundary loss [20], a regional integral weighted by the signed distance map of the ground truth, designed for highly unbalanced problems such as small lesions.
Optional: Three active-contour losses in detail (in the Supplementary notes). How each loss is built and what its authors report.
What deep learning changed, and what it did not:
- Changed: the data term. Hand-made forces (, GVF, , region means) are replaced by learned features. This is the main reason accuracy improved.
- Not changed: the regularity prior. Boundary length, curvature penalties, signed distance representations and region homogeneity reappear as loss terms and output representations, because pixel classifiers still produce ragged, fragmented boundaries without them.
- Not changed: the explicit vs implicit trade-off. Contour-based networks inherit the snake’s fixed topology (one polygon per instance) and its speed; mask and distance-map networks inherit the level set’s flexibility.
- Still useful on its own. When there are no labelled data, a Chan–Vese or GAC run is a few lines of scikit-image and needs no training, which makes it a good baseline, a pseudo-label generator, or a post-processing step that cleans up a network’s mask.
Key takeaways
- An active contour segments by minimizing an energy over curves: a regularity term (length, bending) plus a data term (edges or region fit). Gradient descent on that energy is a PDE in artificial time.
- A snake is an explicit chain of points. Its Euler–Lagrange equation is solved with a semi-implicit step .
- Plain gradient forces have a small capture range and fail in concavities. GVF diffuses edge vectors across the image; the balloon force inflates or deflates the curve.
- A level set stores the curve as and evolves with upwind differences under a CFL step limit. Topology changes are automatic.
- The speed carries the model: geodesic active contours minimize edge-weighted length; Chan–Vese fits two region means and works without edges.
- Keep close to a signed distance (reinitialization or DRLSE), and save work with narrow bands or morphological approximations, which approximate rather than solve the PDEs.
- In deep learning the same ideas survive as learned contour deformation (Deep Snake) and as loss functions built from length, region and signed-distance terms.
Exercises
1. Tension alone. A closed snake with and no external force is initialized as a circle of radius sampled at evenly spaced points. Using the discrete internal force , show that the circle stays a circle and find how its radius changes in one explicit step of size .
Hint
For a regular polygon with angle step , (measured from the centre). The force is , pointing to the centre, so . The circle shrinks geometrically; note that the rate depends on , which is one reason snake parameters are tied to the sampling.
2. Concavity test. Using the gvf function above, build the U shape of Figure 11.2 and vary the GVF weight (0.05, 0.1, 0.2) and the number of GVF iterations. Which parameter controls how far the field reaches from the edges, and which controls how smooth it is?
Hint
The diffusion length grows roughly with , where is the iteration count. A larger also changes the smoothness/data-fit balance. Because the code adapts to both diffusion and reaction, is not automatically unstable; compare equal evolution time or a fixed convergence tolerance when changing .
3. Signs and directions. With our convention ( inside), what happens to a circle under when ? When ? Write the radius in each case.
Answer
: the circle shrinks at unit speed, . : curve-shortening flow, , so , and the circle vanishes at .
4. CFL in practice. Run the evolve snippet with cfl=0.5, 1.0 and 2.0 on the same circle. Measure the final radius and look at the zero contour. What breaks, and why does the narrow band not remove this limit?
Hint
Above 1 the front tries to cross more than one cell per step; upwind information comes from the wrong place and the contour becomes jagged or the values blow up. The narrow band reduces the number of pixels updated, not the size of each step.
5. When Chan–Vese fails. Create a synthetic image whose left half is a smooth gradient from black to white and whose right half contains a gray disc on a gray background of the same mean but different variance (add strong noise only inside the disc). Run chan_vese. Explain the result from the energy, and propose a change of the region model that would succeed.
Hint
Chan–Vese only compares means, so the disc (same mean) is invisible and the ramp is cut in the middle. Modeling each region by a Gaussian with its own mean and variance, as in the statistical framework of [14], makes the disc separable.
6. Energy as a loss. Write the Chan–Vese energy for a soft mask (inside probability) instead of a level set, with the length term replaced by the total variation . Show that for fixed the optimal are weighted means, and explain why this function can be used to train a network without labels.
Hint
. Setting gives . Nothing in refers to ground truth, only to the image itself, so gradients with respect to the network producing exist without labels; compare with [19].
References
- R. C. Gonzalez and R. E. Woods, Digital Image Processing, 4th ed., Pearson, 2018, Ch. 11. publisher page
- M. Kass, A. Witkin, and D. Terzopoulos, “Snakes: Active contour models,” International Journal of Computer Vision, vol. 1, no. 4, pp. 321–331, 1988. doi:10.1007/BF00133570
- C. Xu and J. L. Prince, “Snakes, shapes, and gradient vector flow,” IEEE Transactions on Image Processing, vol. 7, no. 3, pp. 359–369, 1998; see also C. Xu, A. Yezzi Jr., and J. L. Prince, “On the relationship between parametric and geometric active contours,” Proc. 34th Asilomar Conf. on Signals, Systems, and Computers, 2000. GVF project page with both papers
- L. D. Cohen, “On active contour models and balloons,” CVGIP: Image Understanding, vol. 53, no. 2, pp. 211–218, 1991. author PDF
- S. Osher and J. A. Sethian, “Fronts propagating with curvature-dependent speed: Algorithms based on Hamilton–Jacobi formulations,” Journal of Computational Physics, vol. 79, pp. 12–49, 1988. doi:10.1016/0021-9991(88)90002-2
- V. Caselles, R. Kimmel, and G. Sapiro, “Geodesic active contours,” International Journal of Computer Vision, vol. 22, no. 1, pp. 61–79, 1997. PDF
- D. Mumford and J. Shah, “Optimal approximations by piecewise smooth functions and associated variational problems,” Communications on Pure and Applied Mathematics, vol. 42, no. 5, pp. 577–685, 1989. doi:10.1002/cpa.3160420503
- T. F. Chan and L. A. Vese, “Active contours without edges,” IEEE Transactions on Image Processing, vol. 10, no. 2, pp. 266–277, 2001. doi:10.1109/83.902291
- D. Adalsteinsson and J. A. Sethian, “A fast level set method for propagating interfaces,” Journal of Computational Physics, vol. 118, pp. 269–277, 1995. summary page
- C. Li, C. Xu, C. Gui, and M. D. Fox, “Distance regularized level set evolution and its application to image segmentation,” IEEE Transactions on Image Processing, vol. 19, no. 12, pp. 3243–3254, 2010. doi:10.1109/TIP.2010.2069690
- P. Márquez-Neila, L. Baumela, and L. Álvarez, “A morphological approach to curvature-based evolution of curves and surfaces,” IEEE Transactions on Pattern Analysis and Machine Intelligence, 2014. doi:10.1109/TPAMI.2013.106
- scikit-image developers, “skimage.segmentation” API reference (
active_contour,chan_vese,morphological_chan_vese,morphological_geodesic_active_contour). docs - T. McInerney and D. Terzopoulos, “Deformable models in medical image analysis: A survey,” Medical Image Analysis, vol. 1, no. 2, 1996. author PDF
- D. Cremers, M. Rousson, and R. Deriche, “A review of statistical approaches to level set segmentation: Integrating color, texture, motion and shape,” International Journal of Computer Vision, vol. 72, no. 2, pp. 195–215, 2007. doi:10.1007/s11263-006-8711-1
- Y. Chen, P. Ge, G. Wang, and H. Chen, “An overview of intelligent image segmentation using active contour models,” Intelligence & Robotics, vol. 3, no. 1, pp. 23–55, 2023. open access
- S. Bohlender, I. Oksuz, and A. Mukhopadhyay, “A survey on shape-constraint deep learning for medical image segmentation,” IEEE Reviews in Biomedical Engineering, vol. 16, pp. 225–240, 2023. arXiv:2101.07721
- S. Peng, W. Jiang, H. Pi, X. Li, H. Bao, and X. Zhou, “Deep snake for real-time instance segmentation,” CVPR, 2020. arXiv:2001.01629
- X. Chen, B. M. Williams, S. R. Vallabhaneni, G. Czanner, R. Williams, and Y. Zheng, “Learning active contour models for medical image segmentation,” CVPR, 2019. CVF open access
- B. Kim and J. C. Ye, “Mumford–Shah loss functional for image segmentation with deep learning,” IEEE Transactions on Image Processing, vol. 29, pp. 1856–1866, 2020. doi · arXiv:1904.02872
- H. Kervadec, J. Bouchtiba, C. Desrosiers, E. Granger, J. Dolz, and I. Ben Ayed, “Boundary loss for highly unbalanced segmentation,” Medical Image Analysis, vol. 67, 2021 (first presented at MIDL 2019). arXiv:1812.07032
Check your understanding
This tutorial has 6 exercises. Can you solve them without opening the hints?
Go to the exercises ↑Next IP 12 · Feature Extraction · 30 min